Eastern Edge Robotics
Chief Operating Officer (2023-2026) • Software Lead (2022-2023)
Oct 2021 – Jun 2026
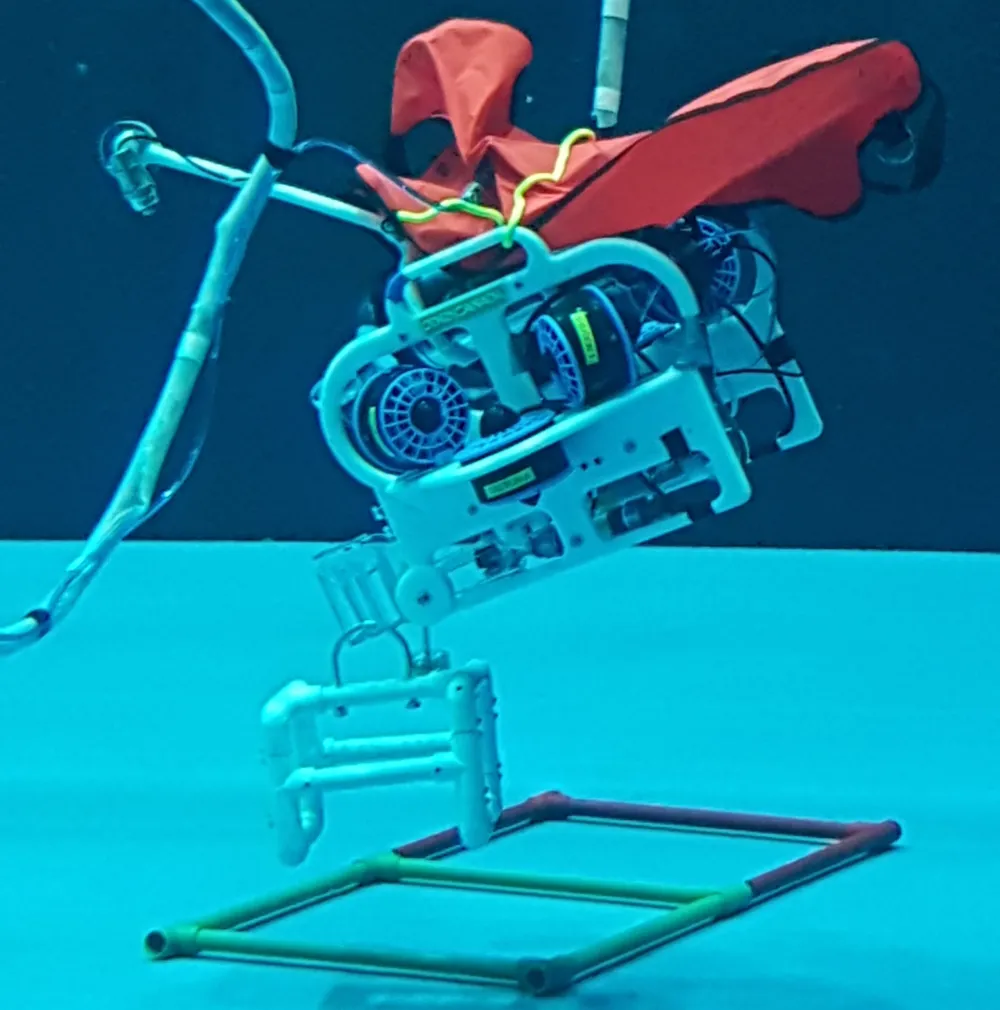
An undergraduate team that designs and operates a Remotely Operated Vehicle (ROV) for the international MATE ROV Competition.
- Led a 35-member cross-functional team (software, electrical, mechanical) to a team 1st-place finish at the 2026 MATE EXPLORER World Championship, owning prioritization and trade-off decisions under a fixed budget and deadline
- Part of the team that placed 1st in Engineering Presentation at the 2022 and 2023 MATE EXPLORER World Championship
- Decided each season which capabilities to build, defer, or cut by weighing technical effort, risk, and competition value
- Served as the link between technical builders and non-technical stakeholders, including sponsors, judges, and university administration
- As Software Lead, architected an ROV control system in Python and ROS2, including a diagnostics GUI and integrated thrusters, servos, lighting, and network communications